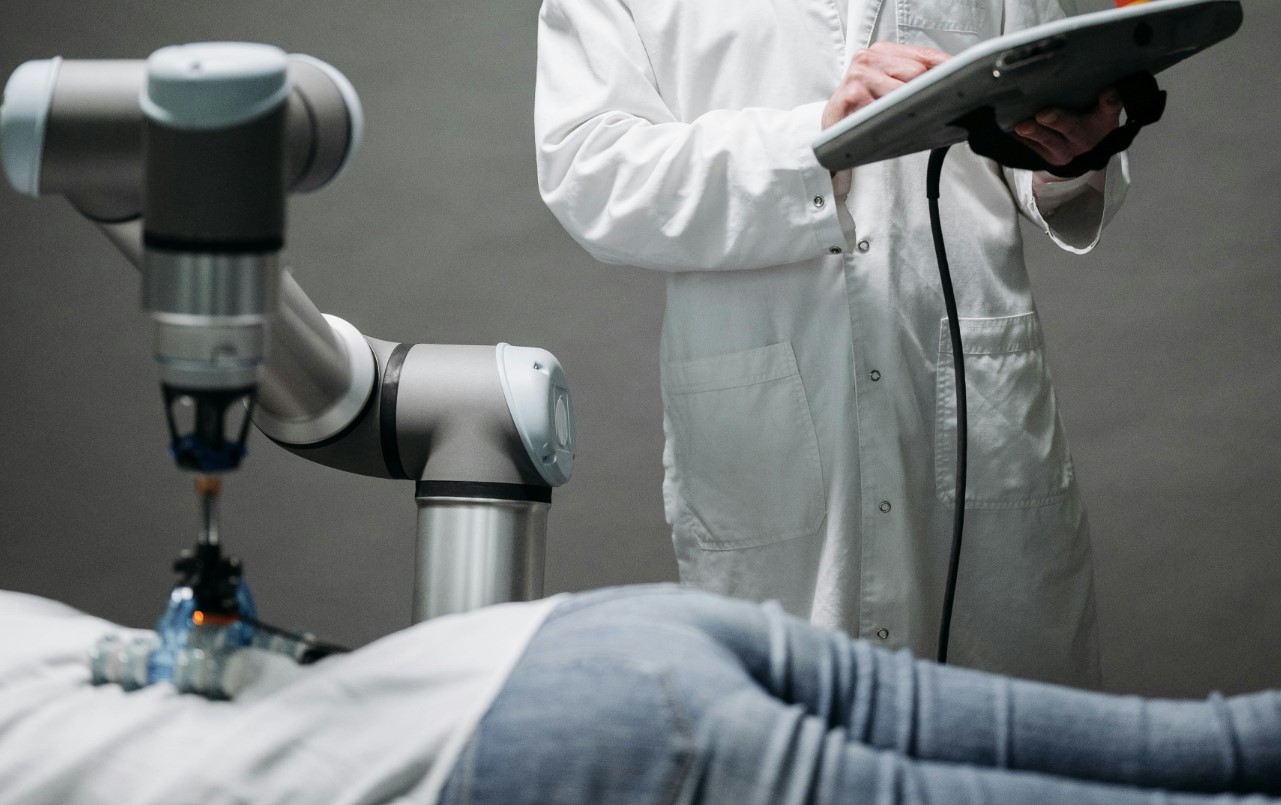
Surgical robots have eliminated the need for long incisions and shaky human hands — but they stripped out something equally important: the surgeon's sense of touch. A EU-funded research consortium called PALPABLE is now building a soft robotic fingertip that uses fibre-optic sensing and AI to reconstruct tactile information in real time, with a first prototype expected in surgeons' hands by March 2026.
- Why Surgical Robots Lost the Sense of Touch
- How the PALPABLE Fingertip Actually Works
- The Clinical Stakes: Tumour Margins and One-Shot Surgery
- What the Haptic Gap Means for Surgical Robot Valuations
- What This Means for Robotics
- Frequently Asked Questions
Why Surgical Robots Lost the Sense of Touch
The transition from open surgery to robotic-assisted minimally invasive surgery delivered measurable patient benefits — shorter hospital stays, reduced trauma, faster recovery — but it introduced a fundamental sensory deficit that the field has largely accepted as an unavoidable trade-off.
Professor Alberto Arezzo of the University of Turin, who has spent three decades treating colorectal cancer patients, traces the problem back to the shift toward keyhole surgery in the 1990s. Long instruments replaced fingers, and physical palpation — the act of pressing and feeling tissue — became impossible. Robotic systems compounded the issue further.
"In robotic surgery, tactile feedback is largely absent," Arezzo told the Horizon EU Research and Innovation Magazine. "That's why this work is so important."
The clinical consequence is not trivial. Tumours typically feel stiffer and less pliable than surrounding healthy tissue — a distinction that an experienced surgeon's fingertips can detect in open surgery but that vanishes entirely when operating through a robotic instrument. Without that tactile signal, surgeons rely on visual information alone, which is an incomplete picture when tissue differentiation matters most.
How the PALPABLE Fingertip Actually Works
The PALPABLE probe uses fibre-optic sensing embedded inside a soft, flexible silicone tip — translating mechanical deformation into light-signal changes that AI software then interprets as a tissue-stiffness map.
Here is the physics: when the silicone dome presses against tissue, it deforms. That deformation alters the intensity and wavelength of light travelling through hair-width fibre-optic cables inside the tip. Dr Georgios Violakis at Hellenic Mediterranean University describes it as mapping "both the direction and the magnitude of the applied force" from a single contact point.
The analogy to structural health monitoring is precise and instructive. The same fibre-optic sensing principle has been used for decades to detect micro-movements in aircraft wings, skyscrapers, and nuclear reactor components — structures where small deformations carry critical safety information. The PALPABLE team is applying identical physics at a dramatically smaller scale: instead of detecting millimetre-scale flex in a bridge, the sensors detect submillimetre differences in how a tumour boundary resists compression. The analogy breaks down at the output stage — bridge sensors flag binary pass/fail states, whereas the surgical probe must produce a continuous, spatially resolved stiffness gradient usable in real-time decision-making.
The output is a colour-coded visual map displayed on the surgeon's console, translating what fingers would previously have felt into something the eyes can interpret.
| Component | Partner Institution | Role |
|---|---|---|
| Soft membrane design | Queen Mary University of London (UK) | Fingertip structure and deformation mechanics |
| Functional films | Fraunhofer Institute (Germany) | Optical sensitivity layer fabrication |
| Stiffness visualisation software | University of Essex (UK) | Real-time tactile mapping interface |
| AI tactile mapping | Bendabl / Tech Hive Labs (Greece) | Signal interpretation and visual output |
| Clinical integration | University of Turin (Italy) / Hadassah Medical Centre (Israel) | Surgical validation and use-case definition |
A first prototype is slated for surgeon testing around March 2026, following lab-based validation. The full research programme runs to the end of 2026.
The Clinical Stakes: Tumour Margins and One-Shot Surgery
Getting tumour margins right is one of surgery's most consequential precision problems — and the one where restored haptic feedback could have the most immediate impact.
Dr Gadi Marom at Hadassah Medical Centre in Jerusalem, who specialises in minimally invasive and robotic surgery for stomach and oesophageal disease, frames the problem bluntly: "We don't want to do that. We want it done in one shot." The "that" he is referring to is re-operation — returning to remove cancer that wasn't fully cleared the first time because the margins were misjudged.
Remove too much tissue and function is compromised. Remove too little and residual cancer cells can proliferate. In oesophageal surgery specifically — already an eight-hour procedure in complex cases — the stakes of a margin error are severe. Marom believes that a stiffness-mapping tool could eventually enable surgeons to resect small oesophageal tumours without removing the entire organ, a procedure currently limited by the inability to confirm margins intraoperatively.
The broader implication is that haptic AI is not just a quality-of-life feature for surgeons. It is a precision tool with direct patient-outcome consequences.
What the Haptic Gap Means for Surgical Robot Valuations
The absence of haptic feedback is a known limitation in current-generation surgical robots, and it is starting to affect how buyers and institutions evaluate both new and used systems.
The da Vinci Surgical System — the dominant platform in robotic surgery — has faced sustained criticism for its lack of force feedback since its original FDA clearance. Newer entrants such as CMR Surgical's Versius and Medtronic's Hugo have similarly launched without meaningful haptic capability. This is not an oversight; integrating accurate tactile sensing into a sterile, instrument-tip environment at surgical scale has been genuinely hard engineering.
The practical result is a two-tier depreciation dynamic on the used surgical robot market:
| System Generation | Haptic Capability | Typical Used Market Discount vs. New |
|---|---|---|
| da Vinci Si / Xi (current gen) | None | 35–55% |
| da Vinci SP | None | 25–40% |
| Emerging systems (post-2026) | Partial / prototype | TBD — premium expected |
Systems without haptic feedback are increasingly being repositioned for high-volume, lower-complexity procedures where tissue differentiation is less critical — cholecystectomies, hernia repairs — while oncological and reconstructive cases where margin precision matters most are where the haptic gap is most acutely felt.
If the PALPABLE prototype validates successfully and moves toward regulatory clearance, it would represent the first retrofit-compatible haptic accessory for existing robotic platforms — potentially extending the useful life of installed systems and altering their residual values. Those evaluating used industrial robots or surgical automation systems should watch this development closely.
What This Means for Robotics
The PALPABLE project is a clear signal that physical AI — systems where machine intelligence mediates direct physical interaction with the world — is moving into some of its most demanding environments yet.
Surgical robotics sits at the extreme end of the precision-consequence spectrum. The sensors must be accurate enough to distinguish a tumour margin from healthy tissue. They must operate inside a sterile field. They must feed real-time information to an AI system that produces clinically actionable output without latency. Getting all three right simultaneously is a harder engineering problem than almost anything in industrial automation.
What is significant here is the sensing architecture. Embedding fibre-optic force sensing inside a compliant (soft) robotic structure — rather than relying on rigid load cells — is an approach increasingly seen across manipulation robotics. As soft robotics matures in surgical contexts, the underlying sensing and AI-interpretation stack will migrate into adjacent domains: prosthetics, rehabilitation robotics, and tactile-feedback cobots handling delicate components in electronics manufacturing.
For anyone tracking the humanoid robots and dexterous manipulation space, the PALPABLE approach to fingertip force sensing is exactly the type of sensing primitive that next-generation robotic hands will need at scale.